Understand the scene.
Connect visual observations with objects, spatial relationships and task intent.
THE NEXT CHAPTER OF PHYSICAL AI
A world understood.
A future built with humanlike machines.
01 / OUR CONVICTION
We believe the next leap in AI will happen beyond the screen. Vexkin's vision brings world models, embodied learning and humanoid systems together—so machines can reason about the physical world, then act within it.
02 / THE VEXKIN PLATFORM
A body to act. A model to anticipate.
A learning loop to improve.
Our proposed product architecture.
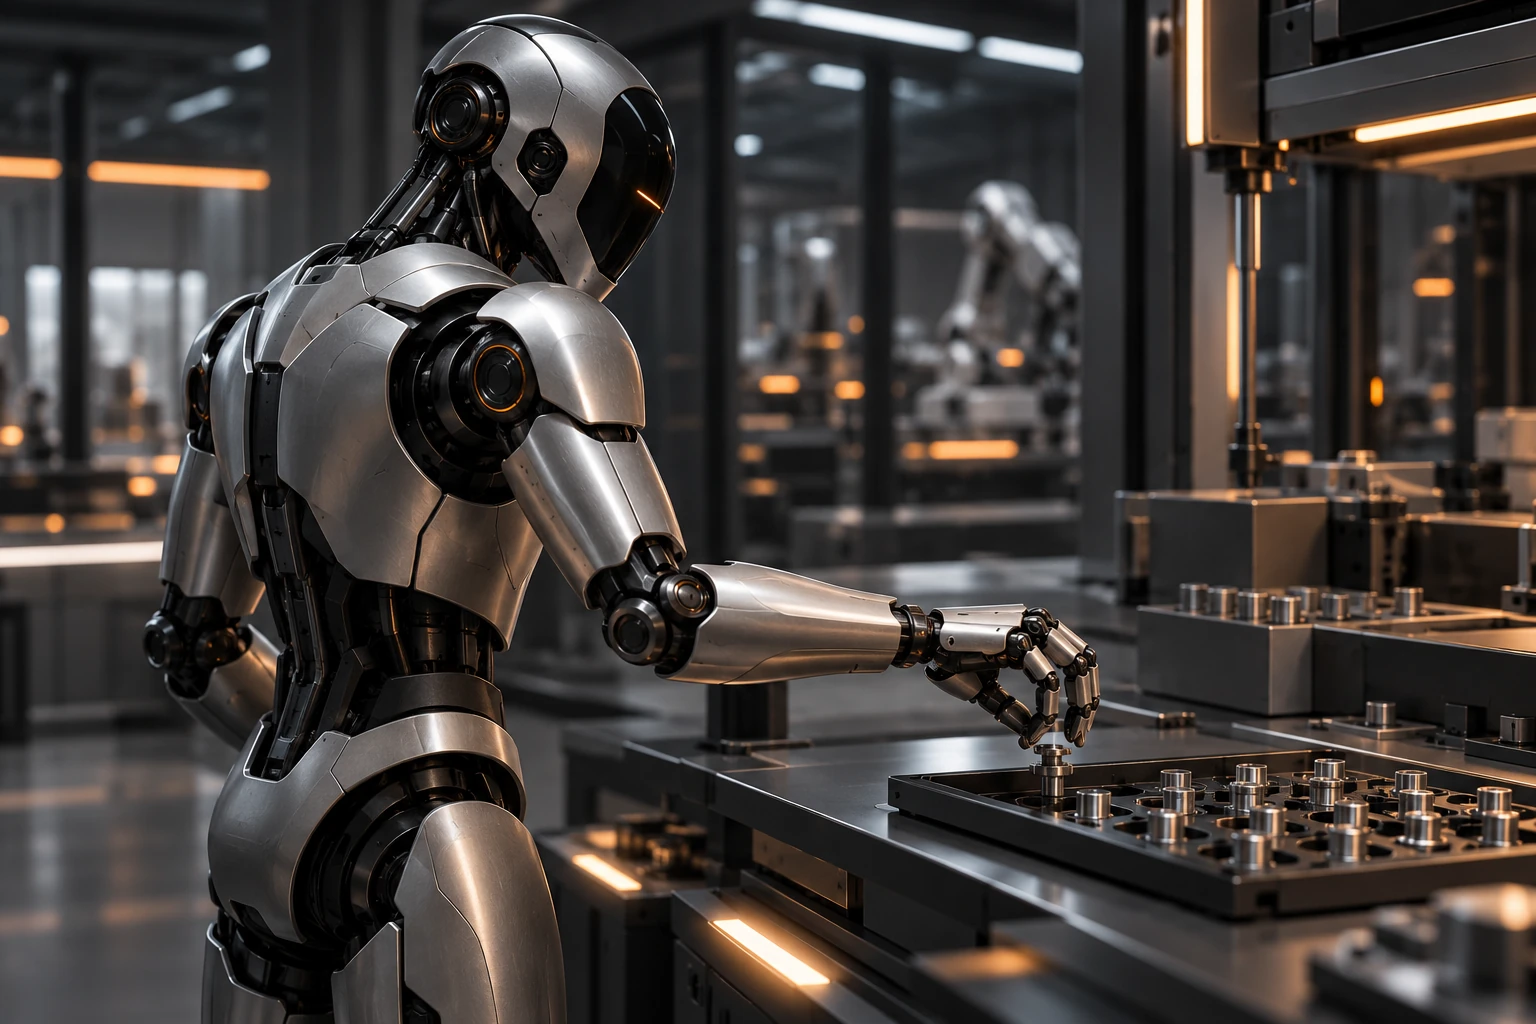
HUMANOID RESEARCH CONCEPT
Our vision for an adaptable humanoid platform: coordinated movement, dexterous manipulation and task-level reasoning in spaces designed for people.
Whole-body coordination
Vision-guided manipulation
Human-supervised operation
Target capabilities. Hardware specifications and performance remain to be validated.
Explore intended applications03 / WORLD MODEL INTELLIGENCE
Our research direction: predict possible outcomes, choose an action, then update the plan as the world changes.
Perception identifies the component, the target and the surrounding workspace.
Connect visual observations with objects, spatial relationships and task intent.
Explore action-conditioned futures before committing to a physical movement.
Use observed outcomes to refine plans and build a stronger learning loop.
04 / THE WORLD AT WORK
We see the starting point in structured, repeatable work—with people in the loop.
Component handling, machine tending and repeatable assembly support.
PROPOSED PILOT DIRECTIONItem sorting, tote transfers and material movement in controlled workspaces.
PROPOSED PILOT DIRECTIONA platform for exploring embodied learning, manipulation and human–robot interaction.
PROPOSED COLLABORATION05 / STANDING ON SCIENCE
Following the ideas moving physical AI forward. Independent work that informs our direction, not Vexkin performance claims.
Whole-body behaviors that transfer to previously unseen homes.
Stage-level prediction for progress through manipulation tasks.
Dense visual representations for spatial and temporal understanding.
Learning from video to understand, predict and plan in the physical world.
Research selection updated 08 October 2026. Referenced authors and organizations are not presented as Vexkin partners.
06 / THE PEOPLE & THE AMBITION
Building the connection between scientific ideas and machines that can do useful work.
OUR NEXT CHAPTER
We're preparing for the next funding conversation: turning a research-led vision into testable systems and focused industrial pilots.
Raised over the past 12 months.
Company-reported · October 2026THIS IS ONLY THE BEGINNING.